Identity
- Status
- active
- Developer ID
openvla/openvla-7b- Released
- Jun 13, 2024
- Version
- 7B
- License
- Unknown

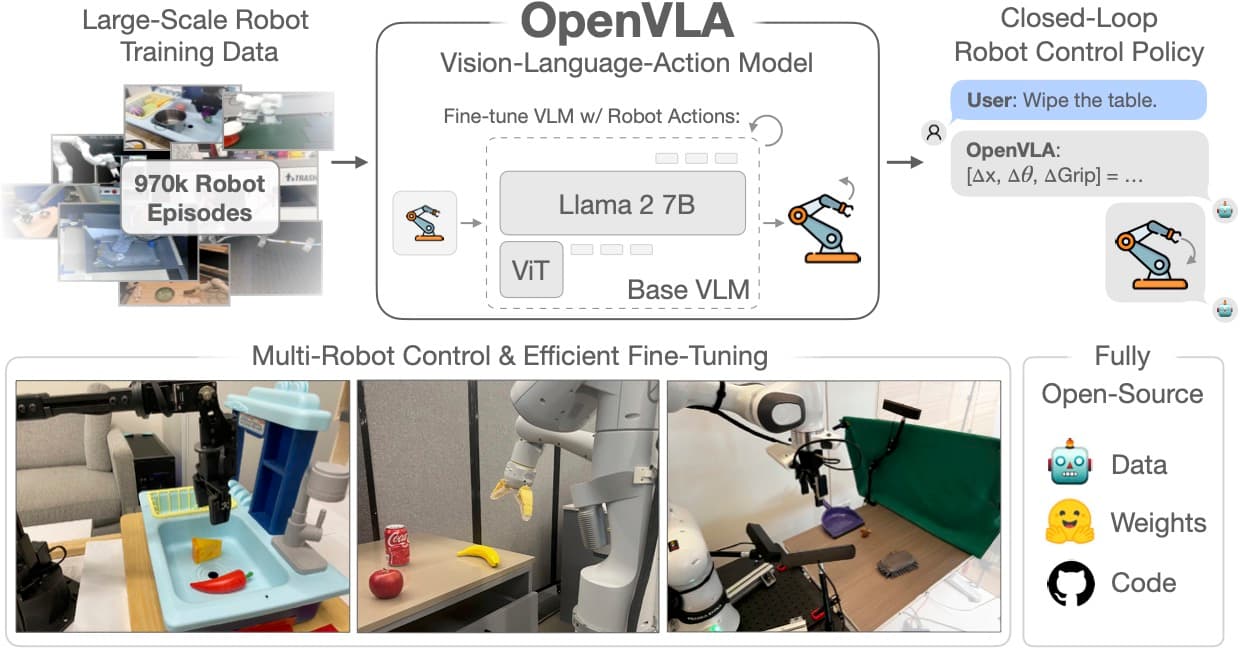
The OpenVLA team's open 7B vision-language-action model trained across Open X-Embodiment robot trajectories.
0 current hosted offerings
This record is downloadable or self-hosted. Its cost depends on the infrastructure and serving configuration, not a universal model price.
At a Glance
openvla/openvla-7bPublisher Media
Embodied Intelligence
970,000 robot manipulation trajectories from Open X-Embodiment described by the authors.
Verified Platform Links
This page represents one developer model product. Dated API snapshots, serving endpoints, pricing, regions, quantizations, and service tiers attach as versioned aliases or provider details and never create duplicate public model records.
Primary Evidence
Comparable Peers
| A | Pair | B | Context |
|---|---|---|---|
OpenVLA 7BOpenVLA Research Team | vs |  MolmoAct 2Ai2 | cross-developer peersrobotics |
OpenVLA 7BOpenVLA Research Team | vs |  Helix 02Figure | cross-developer peersrobotics |
OpenVLA 7BOpenVLA Research Team | vs |  Gemini Robotics 2Google DeepMind | cross-developer peersrobotics |
OpenVLA 7BOpenVLA Research Team | vs |  SmolVLA 450MHugging Face LeRobot | cross-developer peersrobotics |
OpenVLA 7BOpenVLA Research Team | vs |  GR00T N1.7 3BNVIDIA | cross-developer peersrobotics |
OpenVLA 7BOpenVLA Research Team | vs |  pi 0.7Physical Intelligence | cross-developer peersrobotics |
Questions
The OpenVLA team's open 7B vision-language-action model trained across Open X-Embodiment robot trajectories. It is developed by OpenVLA Research Team and its current sourced lifecycle status is active.
OpenVLA 7B's current record lists Text, Image, and Robot state as input and Robot action as output.
OpenVLA 7B is classified as a vision-language-action model. Its action representation is Tokenized actions decoded to continuous robot controls, its control architecture is Fused SigLIP and DINOv2 visual encoder with Llama 2 7B backbone, and inference is recorded as flexible.
The developer reports WidowX, Google Robot, and Franka Panda as supported or represented embodiments. No direct model-to-platform relationship is currently verified in the catalog.
The current record lists 7B total parameters and an unknown active parameter count. Its architecture is Fused SigLIP and DINOv2 visual encoder with Llama 2 7B backbone.
OpenVLA 7B's recorded capabilities are cross-embodiment, fine-tuning, and generalist-manipulation. Its supported tasks are robot-control, dexterous-manipulation, and pick-and-place.
970,000 robot manipulation trajectories from Open X-Embodiment described by the authors.
OpenVLA 7B is explicitly marked as not API-available in the current record.
OpenVLA 7B has no verified hosted API offering, so no provider token price applies. It is a downloadable or self-hosted artifact whose cost depends on the serving infrastructure and workload.
OpenVLA 7B is an open-weight model. Self-hosting is supported, with no license recorded.