

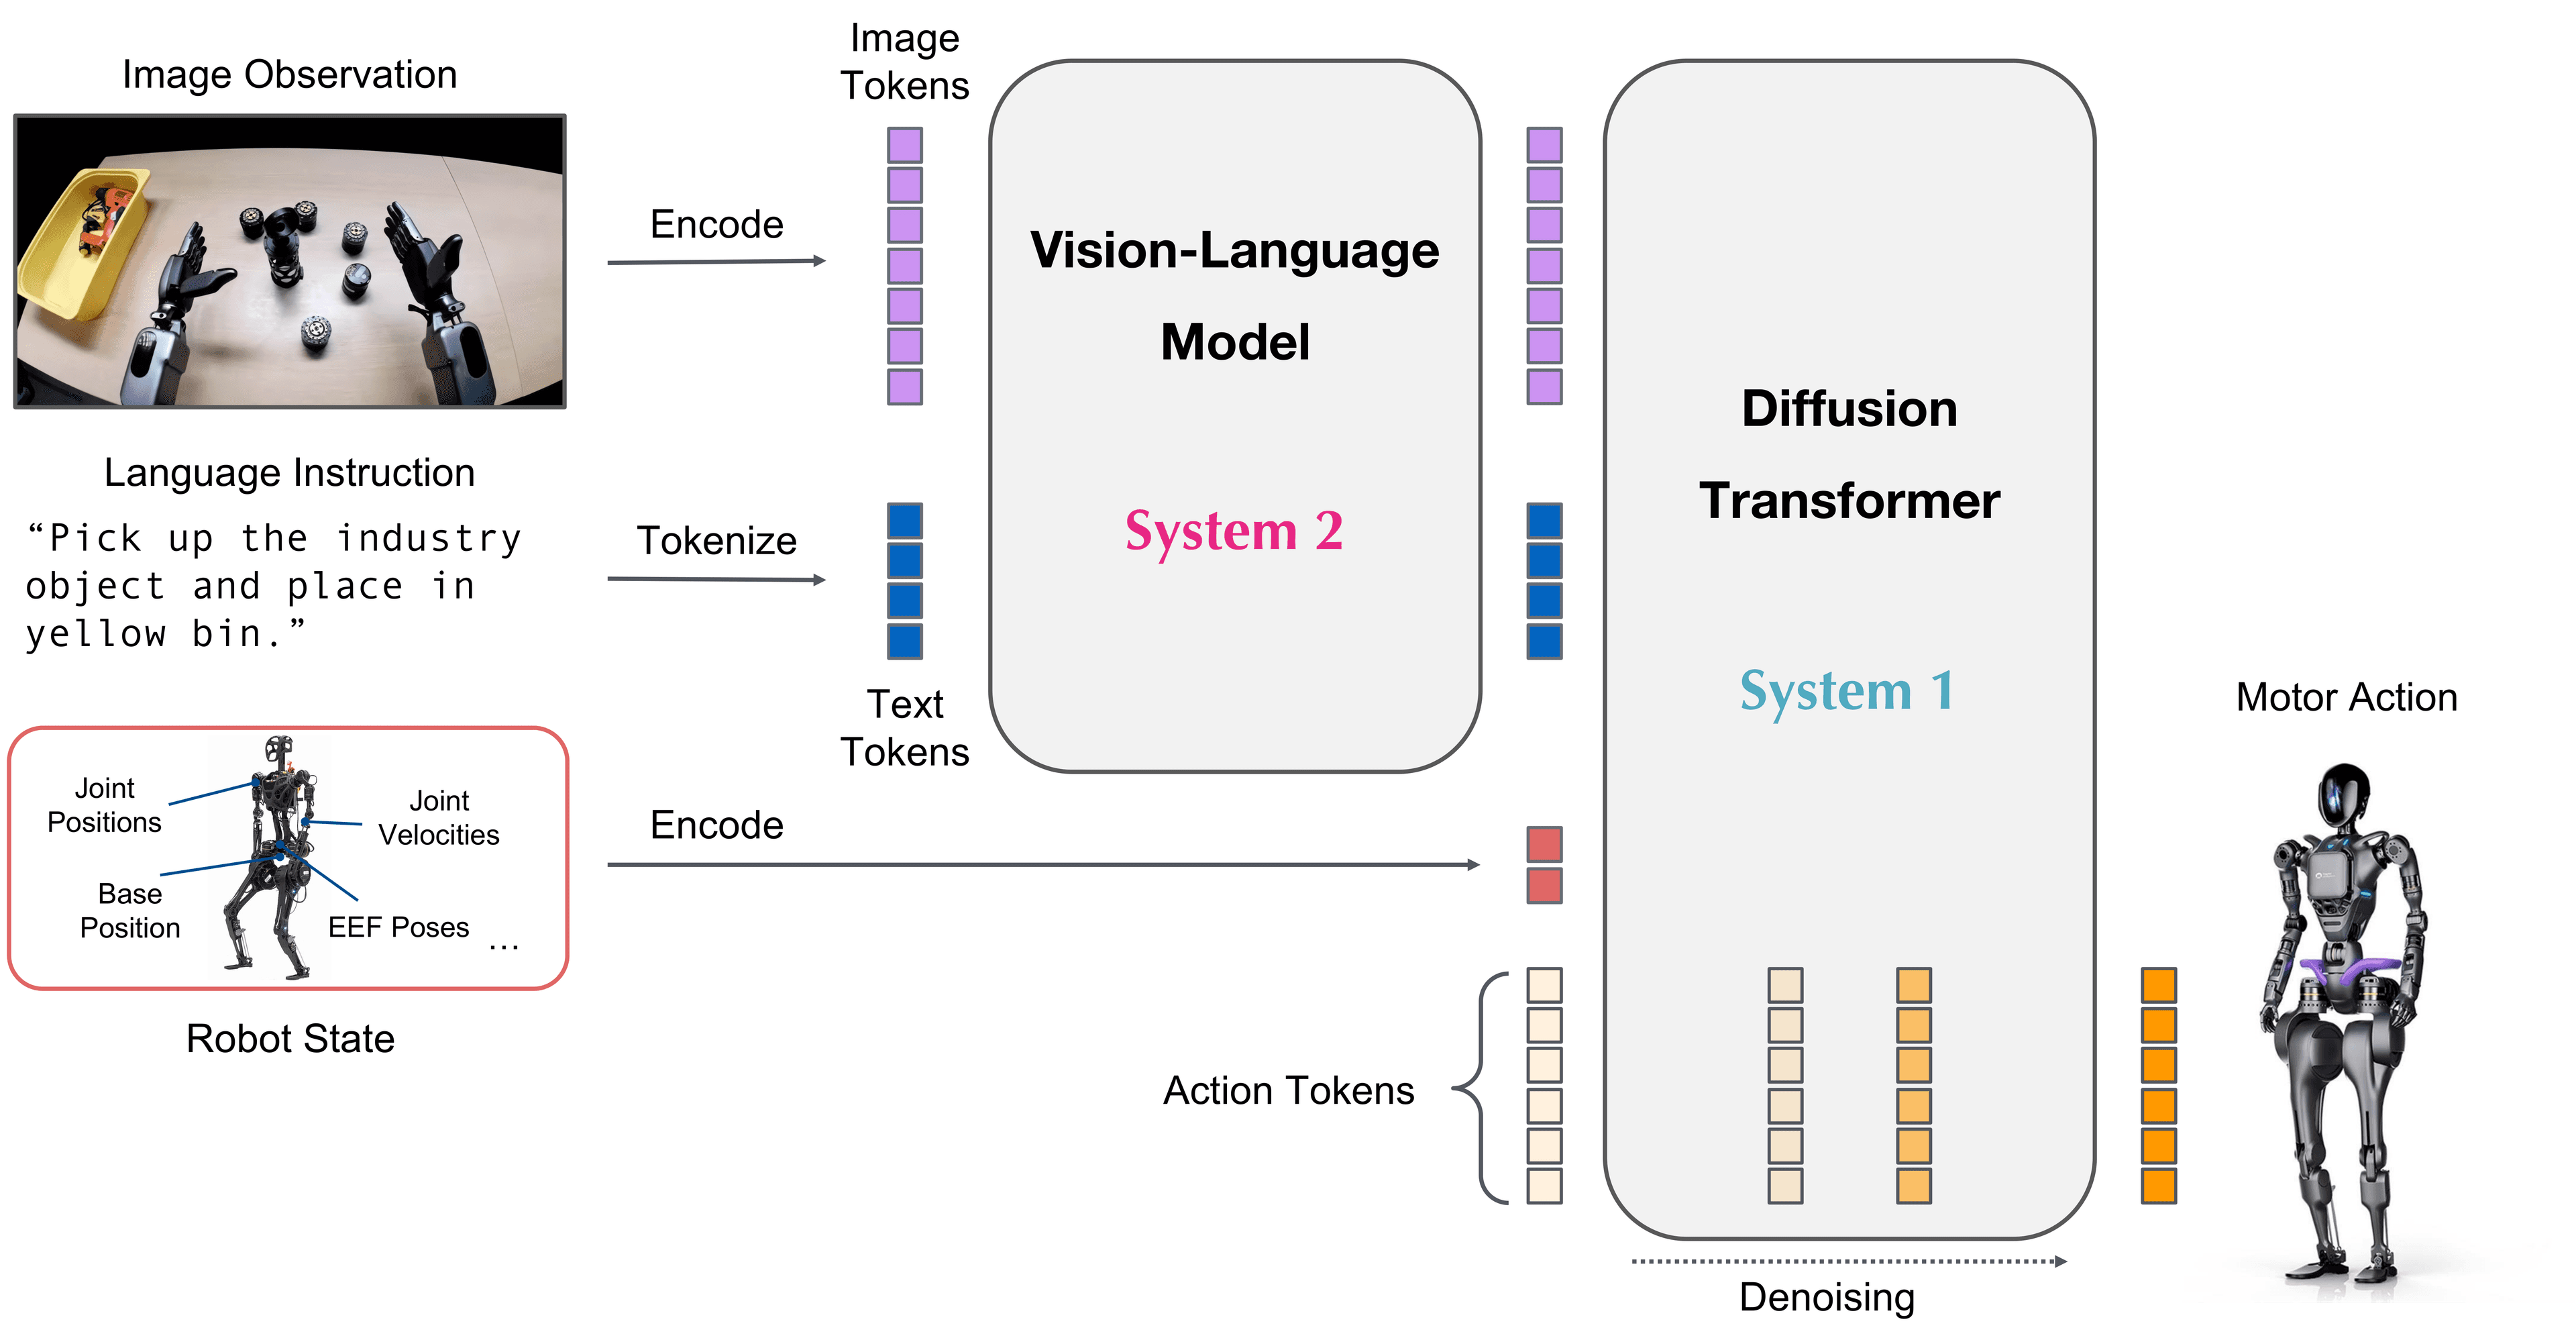
 GR00T N1.7 3BNVIDIA source ↗
GR00T N1.7 3B vs pi 0.7
At a Glance
| Compare |  GR00T N1.7 3BNVIDIA |  pi 0.7Physical Intelligence |
|---|---|---|
| Pricing and Limits | ||
| Context windowMaximum documented tokens | Not reported | Not reported |
| Model facts checked | Aug 29, 2026View model evidence → | Aug 29, 2026View model evidence → |
Available Benchmarks
No Protocol-Matched Benchmark Yet.Results appear here only when both models share the same benchmark version, metric, evaluation protocol, and evidence class.
GR00T N1.7 3BNVIDIA source ↗ pi 0.7Physical Intelligence source ↗
Side-by-Side Facts
| Field | GR00T N1.7 3B | pi 0.7 |
|---|---|---|
| Developer | NVIDIA | Physical Intelligence |
| Family | Isaac GR00T | pi |
| Model | GR00T N1.7 3B | pi 0.7 |
| Version | N1.7 | 0.7 |
| Lifecycle | active | active |
| Released | 2026-07-07 | 2026-04-16 |
| Knowledge cutoff | Unknown | Unknown |
| Input modalities | Text, Image, Robot state | Text, Image, Robot state |
| Output modalities | Robot action | Robot action |
| Context window | Unknown | Unknown |
| Total parameters | 3B | Unknown |
| Active parameters | Unknown | Unknown |
| License | apache-2.0 | Unknown |
| Open weights | Yes | No |
| API available | No | Unknown |
| Self-hostable | Yes | Unknown |
| Provider access | Unknown | Unknown |
| Capabilities | cross-embodiment, dexterous-manipulation, whole-body-control, fine-tuning | cross-embodiment, dexterous-manipulation, language-steering, visual-subgoals |
| Robotics model type | Vision-language-action model | Vision-language-action model |
| Action representation | Predictive chunks of relative joint motions | Continuous robot actions conditioned by multimodal prompts |
| Control architecture | Vision-language backbone with action expert | High-level policy, world model, and action expert |
| Inference location | On device | Unknown |
| Native control rate (Hz) | Unknown | Unknown |
| Supported embodiments | Unitree G1, AgiBot Genie-1, Fourier GR-1, bimanual manipulation platforms | mobile manipulators, bimanual UR5e, multiple fixed manipulators |
| Training data | Mixture of real teleoperation, synthetic robot data, and internet-scale video described by NVIDIA. | Robot demonstrations, autonomous data, egocentric human data, and multimodal web data described by the publisher. |
GR00T N1.7 3B Capabilities
Model typeVision-language-action model
InferenceOn device
Action representationPredictive chunks of relative joint motions
Supported embodiments4
Canonical IDnvidia/GR00T-N1.7-3B
pi 0.7 Capabilities
Model typeVision-language-action model
InferenceUnknown
Action representationContinuous robot actions conditioned by multimodal prompts
Supported embodiments3
Canonical IDphysical-intelligence/pi-0.7
Related Comparisons
All robotics comparisons →| A | Pair | B | Context |
|---|---|---|---|
 MolmoAct 2Ai2 | vs | GR00T N1.7 3BNVIDIA | cross-developer peersrobotics |
 Helix 02Figure | vs | GR00T N1.7 3BNVIDIA | cross-developer peersrobotics |
 Gemini Robotics 2Google DeepMind | vs | GR00T N1.7 3BNVIDIA | cross-developer peersrobotics |
 SmolVLA 450MHugging Face LeRobot | vs | GR00T N1.7 3BNVIDIA | cross-developer peersrobotics |
GR00T N1.7 3BNVIDIA | vs |  OpenVLA 7BOpenVLA Research Team | cross-developer peersrobotics |
Primary Evidence
Sources and Freshness
Questions
GR00T N1.7 3B vs pi 0.7 FAQs
Is GR00T N1.7 3B or pi 0.7 better for coding?+
This comparison does not currently contain a protocol-matched coding benchmark for both GR00T N1.7 3B and pi 0.7, so Model Markets cannot name a coding leader from pricing, context size, or capability labels alone.
Which is cheaper, GR00T N1.7 3B or pi 0.7?+
Neither model has a directly sourced input price in this comparison. Neither model has a directly sourced output price in this comparison.
Which has a larger context window, GR00T N1.7 3B or pi 0.7?+
Neither model has a sourced context window in this comparison, so a larger limit cannot be determined.
Which performs better in benchmarks, GR00T N1.7 3B or pi 0.7?+
There is no overall benchmark winner: At least two independently verified, protocol-matched benchmarks are required for an overall winner.
Can GR00T N1.7 3B or pi 0.7 be self-hosted?+
GR00T N1.7 3B's sourced self-hosting status is supported; pi 0.7's is unknown. An unknown status does not establish support or lack of support. GR00T N1.7 3B is open weight; pi 0.7 is not marked open weight.
Can GR00T N1.7 3B and pi 0.7 understand images?+
GR00T N1.7 3B is documented with image input; pi 0.7 is documented with image input. This reflects supported input modalities, not vision quality.
Which can generate longer answers, GR00T N1.7 3B or pi 0.7?+
Neither model has a sourced maximum output in this comparison, so a larger limit cannot be determined.
Do GR00T N1.7 3B and pi 0.7 support reasoning and tool use?+
GR00T N1.7 3B: image input. pi 0.7: image input. Feature support does not establish relative quality.
Which is available from more inference providers, GR00T N1.7 3B or pi 0.7?+
GR00T N1.7 3B has 0 sourced provider routes; pi 0.7 has 0, a tie.
Which offers better value, GR00T N1.7 3B or pi 0.7?+
There is no universal value winner. Compare the input and output prices above with the matched benchmark result for your workload: cheaper tokens can be offset by different quality, token usage, latency, or provider availability.